Boca Bearings Workshop Weekly Update 14
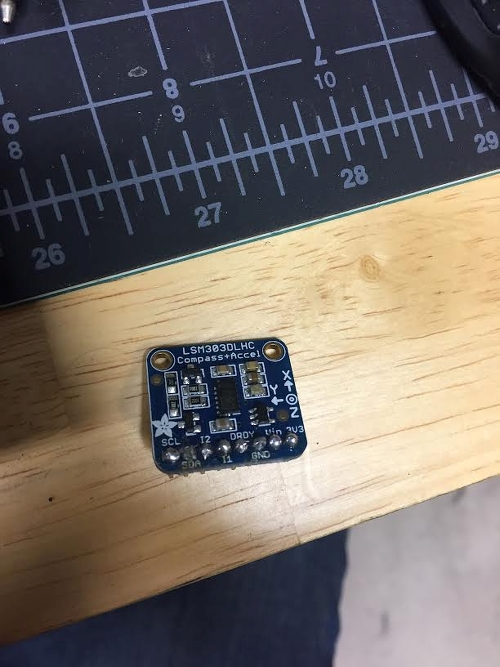
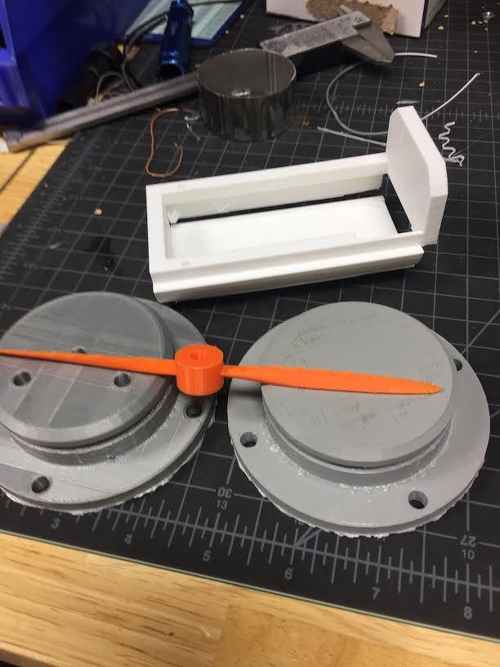
Some final adjustments were made to the hull of the sub. Using Solid works the hull was thickened for strength and and holes were added for the fin rods and mounting plate that hold the two halves of the shell together. The Arduino Uno, battery, and motor holder were 3D printed along with the propeller and end caps for the pressure vessel. The LSM303DLHC compass arrived and the pins were soldered on. Now code can be written and tested for finding the heading and speed.

Power Wheels Racer 2.0: Update 1

Over the past several months us here at The Workshop have been designing and fabricating the next generation of go-kart for our entry into this year’s Power Racing Series event at the Orlando Maker Faire. During last year’s event we found the old kart to simply be too big, too unwieldy, and too slow. Our aim with the new kart was to improve on these three aspects. First, a new frame was designed and welded together. WE salvaged certain parts of the old kart including the steering system and drive shaft but upgraded them with a full wheel in the front (instead of the old handle) and a 48V brushless motor (instead of the old 36V Brushed one). We hoped that the increase in voltage and switch to brushless would allow the kart performance to stay the same or increase while also increasing our run time.
Electric Skateboard Project Update 2

Quick update to the skateboard! In an effort to diagnose issues with another project I needed to salvage some known working parts from something and that turned into me pulling all the electronics out of the electric skateboard. After I was finished with the electronics, I decided to put it all back together but as soon as I looked at the old box full of hot glue, pieces of Velcro, and plastic shavings I decided to remake the box. I took another project box, same as before, and began by taking measurements of the box’s wall and also the three bullet connectors on the esc. I went into Fusion360 and made a bracket to hold the connectors on the inside and outside out the box. The inside bracket clamps down onto the bullet connectors locking the in place and preventing them from sliding around when I try to plug them in.
Boca Bearings Workshop Weekly Update 13

This week I worked on the 3D model for my personal project. The pressure vessel at the center of the design is based from the dimensions of the Arduino Uno microcontroller. The groove in the end caps for the O-ring seals was dimensioned around the #144 O-ring see the parker O-ring manual for more detail. To get the U brackets and fins to turn DC moors with 270 rpm will be hooked up from the pressure vessel and connected with a series of rods and universal joints. The rods in the universal joint will be threaded and when the dc motor spins the u bracket will rise or lower on the rod and pivoted about the fin rods. The universal joints compensate for this pivoted so that the U brackets have a full range of motion of 15 degrees. To seal the rods and stop eater from getting into the pressure vessel 6mm rotary seals are placed into the end cap with the shafts running through it. The drive shaft with the propeller also goes through bearings once they leave the pressure vessel as well as in the back hub. This allows for support of the shafts as well has keeping the rods turning. The Hub was 3D printed and Fins are on the printer.
RC Boat Introduction

I have decided to start on a project to design, fabricate and test a fully functional remote controlled (RC) boat inspired by a 1940’s Chris-Craft. The goal is to be able to remain stable and running for approximately 10 – 15 minutes on a battery pack. This boat will be designed as a semi-displacement hull which will allow it to operate more smoothly at slower speeds. The boat will be engineered with stability and maneuverability in mind. This being said, the boat will be a small scale model of an American classic that can be enjoyed by people of any age, whether it’s enjoyed in a pool, lake or ocean. The motor and other electrical components will be salvaged and modified from a previous RC boat/cars. The hull will be 3D-printed from PLA. Its propulsion will be a single electric motor and propeller that will be directed by a large rudder at the stern. The propeller shaft will be fitted with two small ceramic bearings to insure minimal friction and stress on the electric motor.
Autonomous Submarine Introduction

SECME Mouse Trap Car Racing
Kurtis, a member of the Boca Bearing Workshop Internship program, is also a participant in the Southeastern Consortium for Minorities in Engineering Mouse Trap Car Competition. Additional information on this program can be found here.


Subscribe to:
Posts (Atom)